Built for Real
Emergency Scenarios
Fully distributed architecture — no single point of failure. All processing runs locally on a Raspberry Pi 4B with ESP32 subsystems connected via I²C and MQTT.
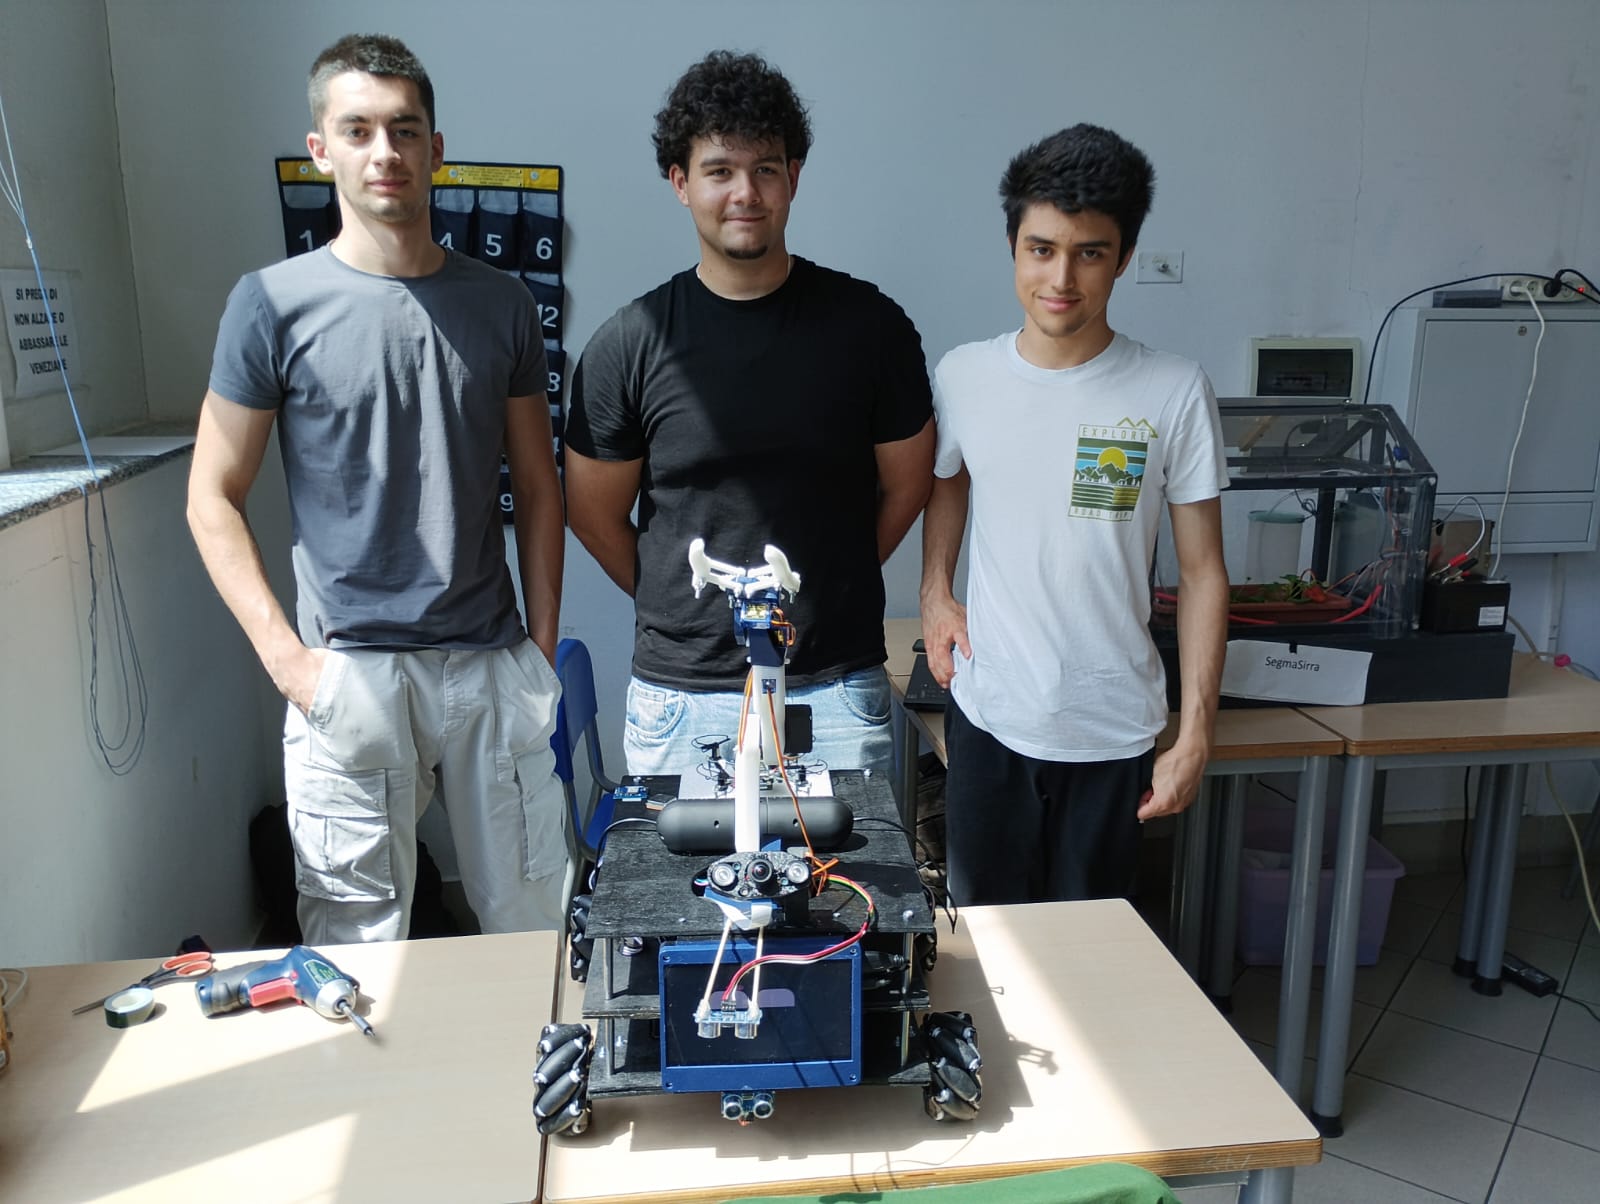
Mecanum Navigation
4 mecanum wheels with quadrature encoders. Full omni-directional movement: strafe, rotate, diagonal — potential field autonomous avoidance.
Details →6-DOF Robotic Arm
MG996R + SG90 servos controlled via PCA9685. Debris removal, object manipulation, relay-activated water pump for firefighting.
Details →Integrated Drone
ESP-Drone companion controlled via CRTP/UDP. Automatic landing watchdog, MQTT bridge, aerial surveillance on demand.
Details →Nova Voice AI
Custom wakeword "Hey Nova" → OpenWakeWord ONNX → Whisper STT → Ollama LLM → Piper TTS. Fully local, zero latency.
Meet Nova →Real-time Mapping
Bayesian occupancy grid from 4 HC-SR04 sensors + encoder odometry. Live GPS track on Leaflet.js web dashboard.
Details →LagmaIpp App
.NET MAUI app for Windows and Android. Dual joysticks, arm sliders, drone control, camera stream — all over Tailscale.
Download →