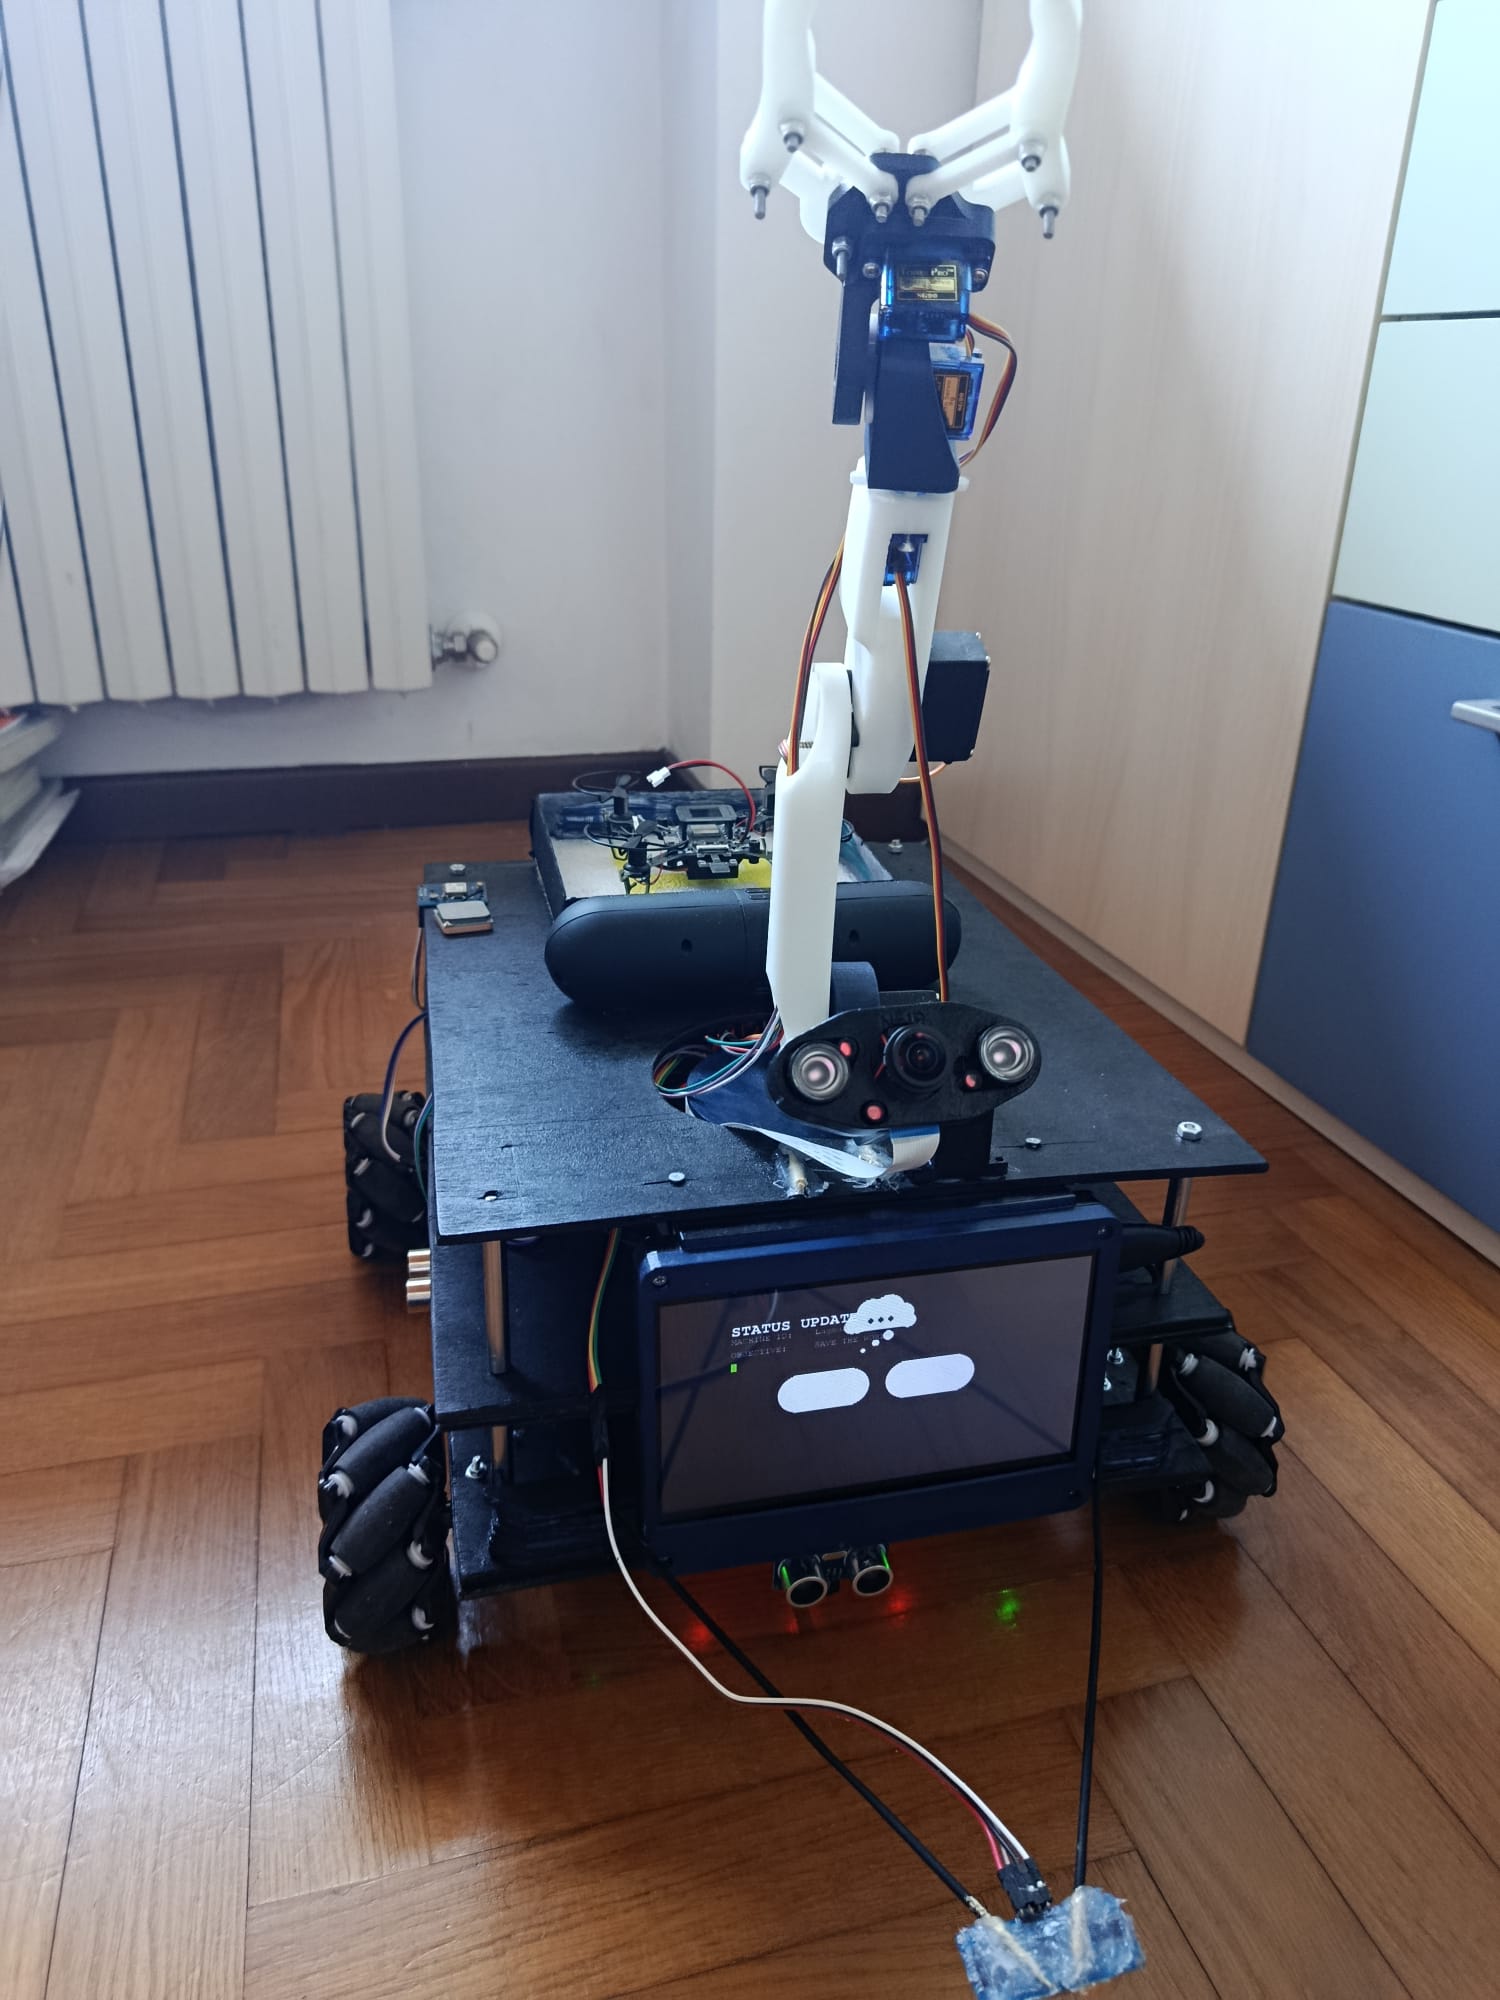
How Nova Works
Wakeword Detection
OpenWakeWord ONNX model (hey_no_va.onnx) runs on CPU via ONNX Runtime. 32ms chunks, 16kHz mono. Threshold 0.7, 3s cooldown to prevent re-triggering. Buffer cleared immediately after detection.
Audio Streaming
Raw PCM16 audio streamed via WebSocket to external server at 100.120.32.86:5000. Pure binary — no headers, no timestamps, no framing metadata. Float32 → int16 LE conversion.
Whisper STT
faster-whisper (int8 quantized, CPU) transcribes the audio to text. Optimized for Italian. Runs on the external PC to offload the Pi.
faster-whisper · int8LLM via Ollama
Transcribed text sent to Ollama running on the external PC. Model selection flexible — Llama, Mistral, Gemma etc. Response streamed back to Pi.
Ollama · local LLMPiper TTS → Speaker
Response synthesized by Piper TTS with the "Miro" Italian voice (~/AIsburra/piper_voci_italiano/Miro/). Audio played via ReSpeaker output (plughw:CARD=seeed2micvoicec,DEV=0).